Almaty info@dji.pro Mon–Sat 09:00–18:00

DJI Zenmuse L3 LiDAR

High-precision LiDAR system for DJI Matrice 400. 1535 nm laser, detection range up to 950 m and two 100 MP RGB cameras. Point cloud and data capture for mapping and 3D modeling.

Description

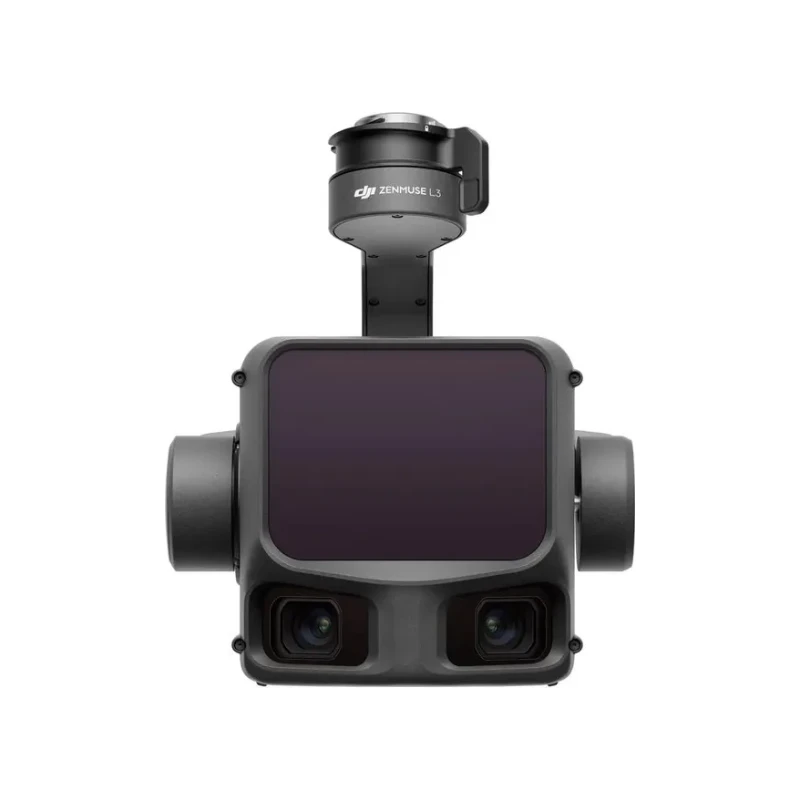
DJI Zenmuse L3 — a next-generation LiDAR system for DJI Matrice 400. It combines a LiDAR, an inertial system and two cameras for comprehensive aerial surveying.

The 1535 nm laser detects objects at up to 950 m and supports up to 16 returns, making it possible to capture terrain data under vegetation. Two 100 MP RGB cameras with mechanical shutters colorize the point cloud and provide images for photogrammetry.

Data is processed in DJI Terra. Suitable for surveying, terrain modeling, power line and infrastructure inspection, forestry and mining.

Key features

  • 1535 nm laser — detection range up to 950 m under DJI test conditions.
  • Up to 16 returns — terrain capture under vegetation.
  • Two 100 MP cameras — mechanical shutters and point cloud colorization.
  • DJI Terra — LiDAR data processing.
  • For Matrice 400 — dedicated L3 gimbal connector.

Compatible devices

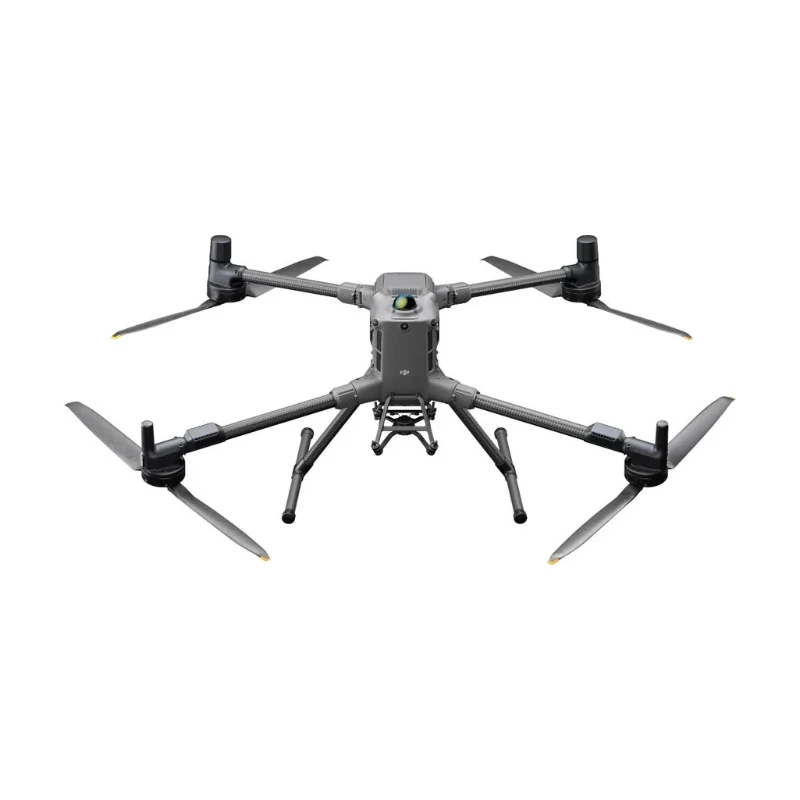
Matrice 300 RTK and Matrice 350 RTK are not supported.

System Specifications

Product NameZenmuse L3
Point Cloud System AccuracyAt 120m Flight Altitude:
Vertical Accuracy: 3 cm (RMSE)
Horizontal Accuracy: 4 cm (RMSE)
At 300m Flight Altitude:
Vertical Accuracy 5 cm (RMSE)
Horizontal Accuracy: 7.5 cm (RMSE)Measured under the following conditions in a DJI laboratory environment: 1. The field contained objects with obvious angular features. DJI Matrice 400 was linked to a position-calibrated D-RTK 3 Multifunctional Station. The flight route was planned using DJI Pilot 2's Area Route (with Calibrate IMU enabled) with Linear scanning. The flight speed was set to 15 m/s, gimbal pitch to -90°, and each straight segment of the flight route was less than 3300 m. 2. Using exposed hard ground checkpoints that conformed to the diffuse reflection model. 3. DJI Terra was used for post-processing with Optimize Point Cloud Accuracy enabled.
Point Cloud Thickness1.2 cm@1σ (120m nadir flight altitude)
2 cm@1σ (300m nadir flight altitude)Measured in Linear scanning mode, using check points on 80% reflectivity objects, with neither point cloud optimization nor downsampling enabled in DJI Terra. For 6σ, multiply the listed thickness by 6.
Combined Horizontal FOV (Dual RGB Mapping Cameras)107°Composed by merging images from two cameras with a 45° optical axis angle between them.
RGB Ground Sampling Distance (GSD)Average Value: 3 cm (300m nadir flight altitude)For detailed calculation methods, refer to the user manual available on the Downloads page of the official DJI Zenmuse L3 webpage.
Weight1.60 kg (without single gimbal connector)The Zenmuse L3 single gimbal connector weighs 145 g.
Dimensions192×162×202 mm (L×W×H)Measured in the default stabilized state after power-on with non-orthogonal gimbal design.
Power64 W (typical)
100 W (max)
Supported AircraftDJI Matrice 400 (requires the Zenmuse L3 single gimbal connector)
Ingress Protection RatingIP54
Operating Temperature-20° to 50° C (-4° to 122° F)
Storage Temperature-40° to 70° C (-40° to 158° F)

LiDAR

Laser Wavelength1535 nm
Laser Beam Divergence0.25 mrad (1/e²)
Laser Spot SizeΦ 41 mm@120 m (1/e²)
Φ 86 mm@300 m (1/e²)
Detection Range700 m@10% reflectivity, 350 kHz
950 m@10% reflectivity, 100 kHz
2000 m@80% reflectivity, 100 kHz1. Range Definition: The range is defined as the distance at which 50% of the emitted laser pulses are detected. If a laser beam hits more than one subject, the total laser transmitter power is split and the achievable range is reduced. 2. Test Conditions: 100 klx ambient light, within the central area of the FOV, using a flat subject with a size larger than the laser beam diameter, a perpendicular angle of incidence, and an atmospheric visibility of 23 km. 3. The maximum detection range is 900 m by default. For a longer range, contact DJI support or an authorized dealer.
Wire Detection Range21.6mm Steel Core Aluminum Stranded Wire:
300 m@100 klx, 350 kHz
18.4mm Black PVC Insulated Wire:
100 m@100 klx, 350 kHz1. Range Definition: The distance at which a fully scanned section of wire in mapping achieves a point density of 4 points per meter. 2. Test Conditions: 100 klx ambient light, 23km atmospheric visibility, LiDAR center FOV perpendicular to the wire, Non-Repetitive scanning mode, drone flying along the wire at 15 m/s, and the wire is clean and not aged.
Ranging AccuracyAbsolute Accuracy: ±10 mm
Repeatability: < 5 mm (1σ)The above specifications can be met under test conditions of 25° C (77° F) ambient temperature, 350 kHz pulse rate, 80% object reflectivity, and distances of 120 m and 300 m. The actual environment may differ from the testing environment. The figure listed is for reference only.
Minimum Effective Detection Distance10 m
Laser Pulse Emission Frequency100 kHz, recommended flight altitude < 500 m
350 kHz, recommended flight altitude < 300 m
1000 kHz, recommended flight altitude < 100 m
2000 kHz, recommended flight altitude < 50 m
Number of Returns4, 8, 16 returns (100 kHz, 350 kHz)
4, 8 returns (1000 kHz)
4 returns (2000 kHz)
Cross-Cycle Calculation7 times
Scanning Mode and FOVLinear Scanning Mode: Horizontal 80°, vertical 3°
Star-Shaped Scanning Mode: Horizontal 80°, vertical 80°
Non-Repetitive Scanning Mode: Horizontal 80°, vertical 80°
Laser Safety ClassificationClass 1 (IEC 60825-1:2014)

RGB Mapping Camera

Sensor4/3 CMOS
LensEquivalent Focal Length: 28 mm
FOV: 73.3° (diagonal), 62° (horizontal), 41.2° (vertical)
Aperture: f/2.0-f/11
ShutterMechanical Shutter: 2-1/1500 s (f/2.0), 2-1/2000 s (f/2.8-f/11)
Shutter Count: 500,000
Electronic Shutter: 2-1/16000 s
Photo Size100 MP: 12288×8192
25 MP: 6144×4096
Minimum Photo IntervalJPEG:
25 MP: 0.5 s
100 MP: 1 s
RAW or JPEG + RAW:
1.2 s
Video SpecificationVideo Format: MP4 (MPEG-4 HEVC/H.265)
Resolution:
4K: 3840×2160@30fps
FHD: 1920×1080@30fps

Position and Orientation System (POS)

GNSS Update Rate5 Hz
POS Update Rate200 Hz
Attitude ErrorYaw Angle: 0.02° (post-processed, 1σ)
Pitch/Roll Angle: 0.01° (post-processed, 1σ)
Positioning AccuracyHorizontal Accuracy: 1.0 cm + 1 ppm (RTK fix)
Vertical Accuracy: 1.5 cm + 1 ppm (RTK fix)
Supported PPK Differential Data FormatsDAT: Generated in Base Station Mode by D-RTK 3 Multifunctional Station and D-RTK 2
RINEX: v2.1x, v3.0x
RTCM: v3.0, v3.1, v3.2, v3.3 (protocols: MSM3, MSM4, MSM5, MSM6, MSM7)
OEM: OEM4, OEM6For field operation, ensure the distance between the Multifunctional Station and the aircraft does not exceed 15 km, and the Multifunctional Station supports satellite observation with more than two GNSS constellations.

Gimbal

Degrees of Freedom3-axis (pitch, roll, yaw)
Angular Accuracy±0.01°
Mechanical RangePitch: -135° to +73°
Roll: -90° to +60°
Yaw: -105° to +105°Structural limit, not controllable range.
Controllable RangePitch: -120° to +60°
Yaw: -80° to +80°Roll is uncontrollable, for stabilization only.
Self-Check MethodRoll Axis: Self-check not required
Yaw Axis: Checks using limit stop
Pitch Axis: Self-check not required
Mounting MethodDetachable DJI SKYPORT (Zenmuse L3 single gimbal connector)

Data Storage

Raw Data StoragePhoto/IMU/Point cloud/GNSS/Calibration files
Standard Memory CardCFexpress™ Type B Memory Card, sequential write speed 1500 MB/s
Standard Card ReaderRead/write speed > 900 MB/s

Software Ecosystem

Data CollectionDJI Pilot 2
Data ProcessingDJI Terra
Data ApplicationDJI Modify
Cloud ApplicationDJI FlightHub 2
Data FormatDJI Terra supports exporting point cloud models in the following formats:
Standard Point Cloud Format: PNTS/LAS/LAZ/PLY/PCD/S3MB
DJI Modify supports importing point cloud models in the following formats:
Standard Point Cloud Format: LAS

Specifications are based on official DJI data (enterprise.dji.com/zenmuse-l3/specs). Actual values may vary depending on operating conditions and firmware version.